Just as in the 2-D case, 3-D rotations operations do not compose together well. They require a mixture of
matrix multiplications and vector additions.
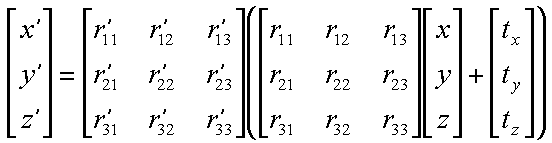
Once again we can solve this problem by embedding our 3-D space within a 4-dimensional space that excludes the
origin. The origin has several properties that make it undesirable. For instance, it is perpendicular to all vectors.
We will also normalize points in this 4-D space by identifying all points that lie on lines through the origin. If we
exclude the origin from this space then every point is uniquely defined.
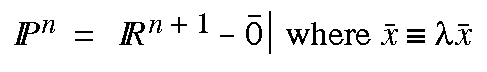 This type of representation is called a projective space.

