There is another way that I beleive is both easier to understand and provides
you with more insights into what rotation is really about. Instead of specifying
a rotation by a series of canonical angles, instead we will specify an arbitrary
axis of rotation and an angle.
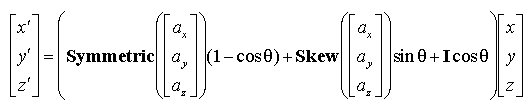
The vector a specifies the axis of rotation. This axis vector must be
normalized. The rotation angle is given by q.
You might ask "How am I going to remember this equation?". However, once
you understand the geometry of rotation, the equation will seem obvious.
The basic idea is that any rotation can be decomposed
into weighted contributions from three different vectors.

